
The essential answer
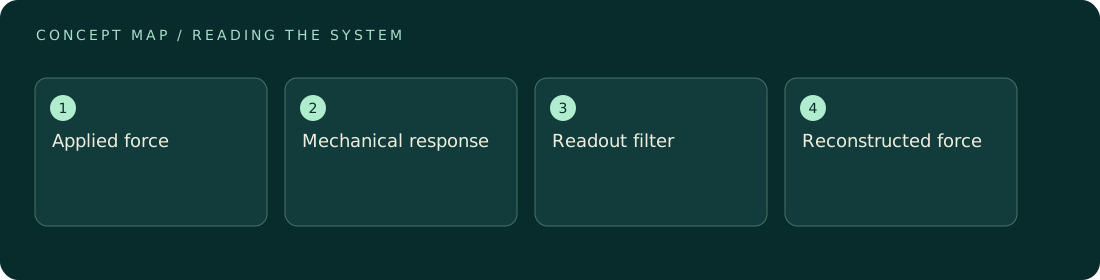
A transfer function describes how an input produces an output as a function of frequency, including both amplitude and phase. A compliant force sensor may obey x = F/k at low frequency, but near resonance its displacement can be much larger and phase shifted. Electronics add further filtering and delay. To infer force from a modulated displacement, divide by the appropriate complex response, including its uncertainty. A static calibration alone is insufficient whenever the chosen frequency lies outside a demonstrated quasistatic regime.
How to reason about it
For a linear damped oscillator, the force-to-displacement response is H(ω) = 1/(k−mω²+i bω), under a specified Fourier convention. The low-frequency limit is 1/k; inertia dominates sufficiently above resonance. Additional modes, feedback, readout filters, and mounting compliance can modify this simple model. Measure the assembled system using a known perturbation across the relevant frequency band and inspect both magnitude and phase residuals. An excellent fit at one frequency can hide parameter degeneracy. Verify linearity by changing drive amplitude, since saturation or friction makes a single transfer function inadequate. If the sensor is operated in feedback, distinguish open-loop plant response from the closed-loop response actually used to reconstruct force. Keep the calibration configuration and loading close to the science configuration, because attaching a cable or changing a mirror can shift resonances.
ILLUSTRATIVE · NOT A REPORTED RESULT
An example to work through
Assume an illustrative oscillator has stiffness k = 1 N/m and mechanical quality factor Q = 50. At frequencies well below resonance, a 1 nN force gives 1 nm displacement. At resonance, the ideal single-mode amplitude is approximately QF/k = 50 nm. Applying the static formula to that resonant motion would incorrectly infer 50 nN. The dynamic calibration recovers 1 nN after accounting for response magnitude and phase. This estimate assumes linear damping, an isolated mode, and sinusoidal steady state; it is not appropriate during ring-up or near overlapping modes.
Where interpretation fails
Do not interpret a larger resonant displacement as an increased applied force. Resonance changes susceptibility. A changing damping rate can alter the measured amplitude even when force is fixed, so power-dependent heating or pressure-dependent damping may masquerade as force changes unless the response is tracked.
The next decision
Use a static conversion only after demonstrating negligible dynamic correction at the measurement frequency relative to the uncertainty target. Otherwise calibrate the complex response in situ and propagate parameter uncertainty. Repeat checks after configuration changes, and reject operating points where model residuals or nonlinear response dominate the desired precision.
Sources & context
These sources support the concepts noted below. Our synthetic examples and research framing are educational interpretation; they are not findings from these organizations or validation of our ventures.
- Finesse: Radiation pressure example ↗
Force-to-displacement frequency response; documentation opened.
Source check: Relevant excerpt or resource metadata checked; see support note. Original illustrative calculation, not source data.
Educational research context, not a validated device specification or clinical protocol. Read our editorial and correction policy.